¶ Technical Specifications
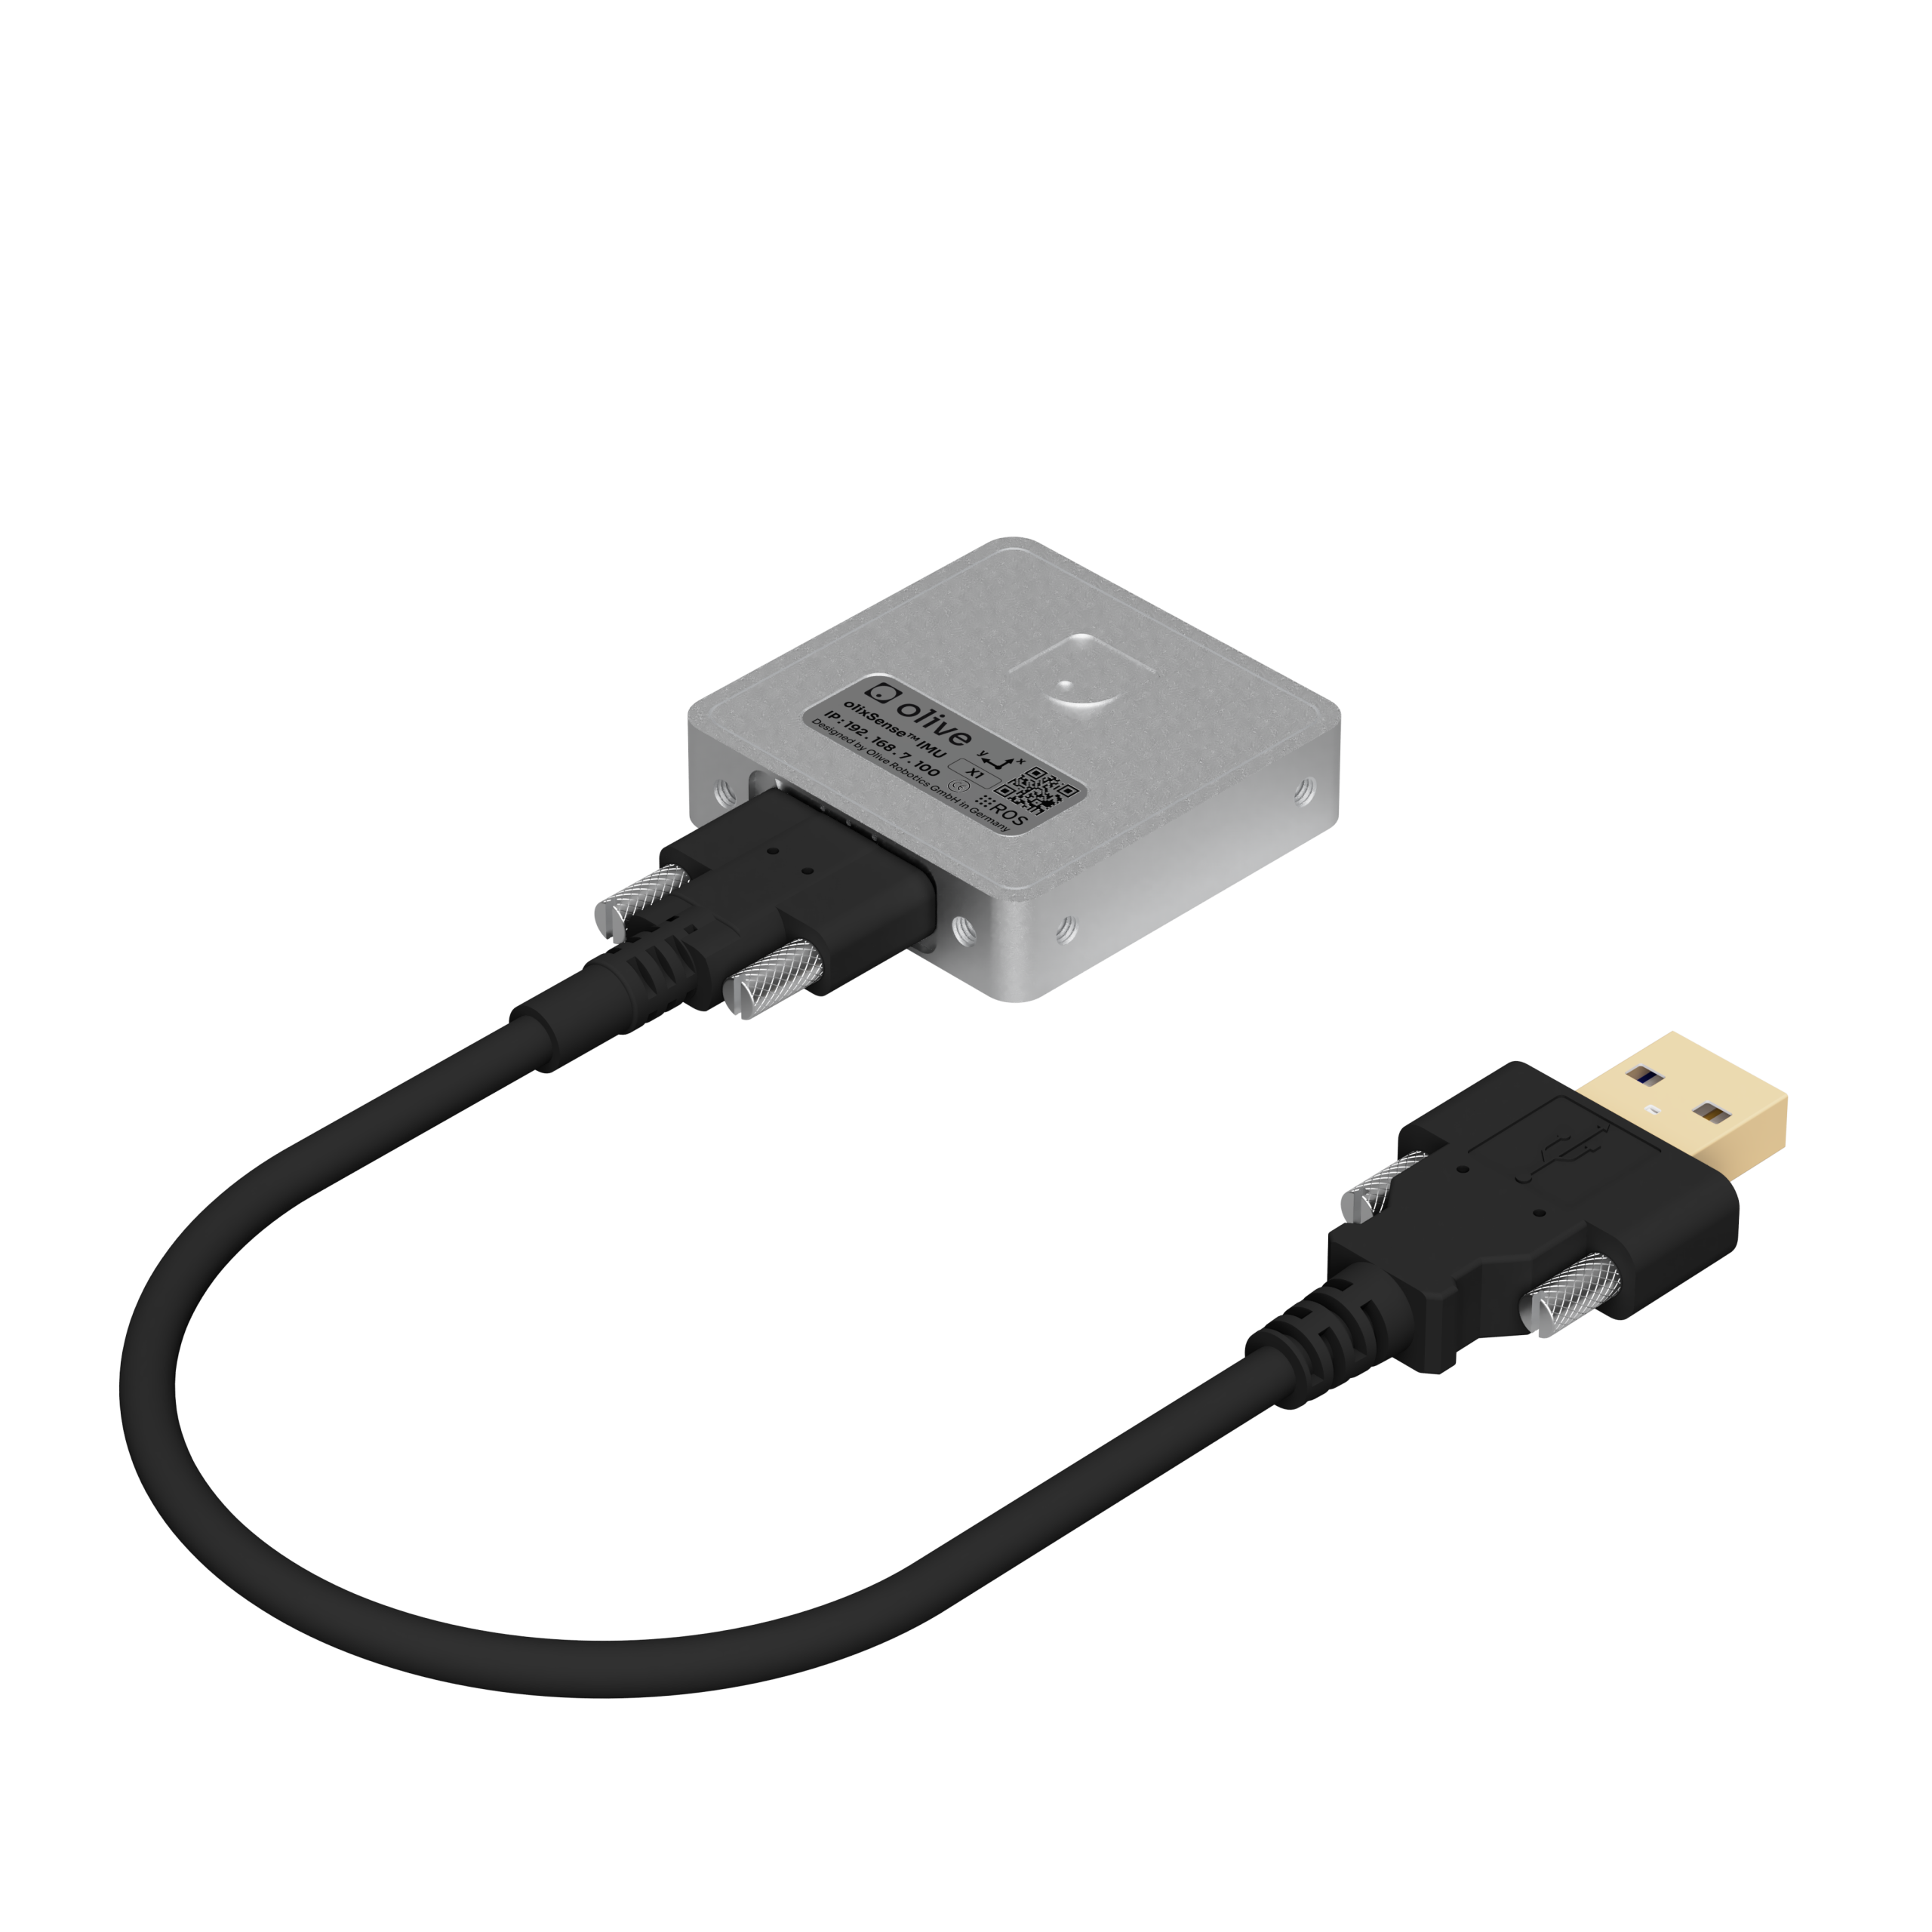
¶ Hardware and operation
| Parameter | Verified observation |
|---|---|
| Maximum output | 1000 hz |
| ROS configuration | ROS 2 Humble/Jazzy |
| ROS RMW DDS supported | rmw_fastrtps_cpp, rmw_cyclonedds_cpp & rmw_zenoh |
| ROS 1 Support | Only via bridge |
| ROS 2 Support | Native |
| Connection | USB-C for power and data |
| Bare-unit weight | 32g |
| Running power | 0.88–0.93 W |
| Startup power | 1.2 W (typical); 1.8W (max) |
| Temperature test | −20 to 80 °C |
| Interface LEDs | 3: Heartbeat, User, System |
| Specification | Accelerometer | Gyroscope | Magnetometer |
|---|---|---|---|
| Range | ±2, ±4, ±8, ±16 g | ±125, ±250, ±500, ±1000, ±2000 °/s | X/Y: ±1300 µT; Z: ±2500 µT |
| Resolution | 16-bit; 0.061 mg/LSB at ±2 g | 16-bit; 0.0038 °/s/LSB at ±125 °/s | 0.3 µT device resolution |
| Sensitivity | 2048 LSB/g at ±16 g | 262.144 LSB/(°/s) at ±125 °/s | — |
| Sensitivity error / gain error | ±0.4% at 25 °C, ±8 g | ±2% at 25 °C | ±5% typical; ±8% maximum after API compensation at 25 °C |
| Zero-g offset | ±20 mg at 25 °C | — | — |
| Zero-rate offset | — | ±0.5 °/s at 25 °C | — |
| Zero-field offset | — | — | ±40 µT at 25 °C; typically ±2 µT after fusion-mode calibration |
| Nonlinearity | 0.5% FS at ±2 g, 25 °C | 0.01% FS at ±250 or ±2000 °/s, 25 °C | 1% FS |

Static orientation error at 200 Hz
| Mode | Axis | Measured result |
|---|---|---|
| AHRS | Roll | 0.2956° RMSE |
| AHRS | Pitch | 0.5475° RMSE |
| AHRS | Yaw | 0.4419° RMSE |
| IMU | Roll | 0.3298° RMSE |
| IMU | Pitch | 0.3214° RMSE |
| IMU | Yaw | 0.1307° RMSE |

Dynamic orientation error at 200 Hz
| Mode | Axis | Measured result |
|---|---|---|
| AHRS | Roll | 1.0219° RMSE |
| AHRS | Pitch | 1.1204° RMSE |
| AHRS | Yaw | 1.7747° RMSE |
| IMU | Roll | 0.9147° RMSE |
| IMU | Pitch | 1.1090° RMSE |
| IMU | Yaw | 1.3451° RMSE |
System Performance
¶ IMU Noise and Random Walk Parameters
¶ Accelerometer
| Parameter | Value |
|---|---|
| Noise Density | 89.895 µg/√Hz |
| Velocity Random Walk | 0.052895 m/s/√hr |
| Bias Instability | 0.0004337 m/s² |
¶ Gyroscope
| Parameter | Value |
|---|---|
| Noise Density | 0.007504 °/s/√Hz |
| Angular Random Walk | 0.45025 °/√hr |
| Bias Instability | 4.8645 °/hr |